





Skip to content
View sepahead's full-sized avatar
🐳
building something great.
🐳
building something great.

Block or report sepahead

Block user

Prevent this user from interacting with your repositories and sending you notifications. Learn more about blocking users.

You must be logged in to block users.

Content in all repositories owned by your account will be closed.
Maximum 250 characters. Please don’t include any personal information such as legal names or email addresses. Markdown is supported. This note will only be visible to you.
Report abuse

Contact GitHub support about this user’s behavior. Learn more about reporting abuse.

Report abuse
sepahead/README.md

Sepehr Mahmoudian, Senior AI Engineer in Berlin building domain-specific AI agents and custom harnesses for auditable research and engineering, with work spanning LLM/VLM evaluation, computational neuroscience, robotics and multimodal 3D perception. Rust and Python; GitHub member since 2014.

Sepehr Mahmoudian on LinkedIn — Senior AI Engineer in Berlin    Sepehr Mahmoudian on Google Scholar — research publications    Sepehr Mahmoudian on Substack — @torusprime, notes and essays    Sepehr Mahmoudian on Hugging Face — @torusprime, datasets    Sepehr Mahmoudian on X (Twitter) — @SepAhead

Curriculum Vitae · English  ·  Lebenslauf · Deutsch

The pulse — GitHub contribution activity

Annual contributions from 2014 to present, with 2014–2022 grouped into a single history bar and a running cumulative total; the highest year so far glows, its in-progress status is explicitly qualified, the year in progress carries a dashed cap, average growth is qualified with its base year, the next year sits as an empty dashed placeholder and the following year as an unstarted future runway slot, with the visual phase motif resolving between them into 20 rays of light streaming from above into the future.

Weekday contribution share: a donut of each weekday's percentage of the last ~16 months (500 days) of contributions; the glowing slice marks the peak day.

Selected work — computational neuroscience, robotics, 3D and scientific software projects

engram: Engram runs experiments with biophysical and functional neural models. An AI agent and custom harness record model sources, simulation inputs, and results. Its optional NCP controller connects NEST networks to the CREBAIN body simulation. The public repository remains a placeholder pending source publication. The source is in the private Paper2Brain repository. NCP: NCP defines typed messages for neural controllers, simulations, sensor monitors, and experiment capture. Each program keeps its own process and state. An application selects the programs that it needs. Engram, CREBAIN, Prisoma, and Galadriel exchange requests and results through NCP. Haldir authorizes commands through its own NCP 1.0 interface. Languages: Rust, TypeScript, Python, C, C++.
prisoma: Prisoma develops experiments for action-conditioned world models. Its Agent Bridge records each command and the original NCP exchanges. You can replay and analyze each experiment from these records. Prisoma uses pid-rs for optional information analysis of CREBAIN sensor recordings. Languages: Rust, Python. crebain: CREBAIN is a standalone drone simulation with RGB images, microphone pressure, and thermal radiance. It is also a platform for sensor-fusion research. Optional NCP interfaces connect it to Engram neural controllers, the Prisoma recorder, and the Galadriel sensor monitor. Its scenes can use meshes from cobot-atlas and relief-atlas and Gaussian splats that Melkor converts. Languages: Rust, TypeScript.
melkor: Melkor provides deterministic 3D Gaussian Splatting (3DGS) conversion across PLY, SPZ and glTF. Its inspection reports surface field provenance, bounds and numeric hazards without modifying source assets. The current release candidate is source-only; no production binary is currently supported. Languages: C++, Python, JavaScript. galadriel: Galadriel is an optional Rust monitor for possible sensor tampering and persistent measurement anomalies. It compares predictions with measurements, examines changes over time, and checks agreement between sensor modalities. When the evidence is not sufficient, it reports this. An alert does not identify its cause. Its NCP adapter records assessments and has no command authority. Galadriel uses pid-rs for information diagnostics. Languages: Rust.
pid-rs: pid-rs is a safe-Rust library for shared-exclusions Partial Information Decomposition and mutual-information estimation: categorical SxPID, KSG MI and default-off experimental continuous shared-exclusions/PID surfaces. v0.9.0 is a GitHub-only source-review prerelease. Languages: Rust, Python. haldir: Haldir Gate authorizes mission commands one at a time. It checks each signed controller intent against held authority, trusted state, replay history, and a deterministic policy. It publishes only its own command frames and records a receipt for each decision. It speaks NCP 1.0 with a lease that it issues. It operates outside the local four-program composition. Languages: Rust.
manwe: Manwe is an airspace-perception research workbench for vision, audio, multi-camera geometry, and multi-target tracking. It has a Python numerical and training package and Rust/Candle inference benchmarks. It makes candidate perception outputs for systems such as CREBAIN. Languages: Python, Rust. cortexel: Cortexel is an unreleased TypeScript library and CLI for neural-simulation figures: it validates and canonicalizes strict declarative JSON requests with fail-closed provenance, then returns deterministic SVG plus a complete exact-value table. main is 0.10.0-dev.0; v0.9.0 is the last tagged preview. Languages: TypeScript.
relief-atlas: relief-atlas is a Python generation pipeline and 10,079-item manifest and prompt catalog for disaster-relief, humanitarian-aid and civil-protection meshes. The repository currently contains 125 GLBs, not a complete 10,079-mesh corpus. Languages: Python. cobot-atlas: cobot-atlas is a Python generation pipeline for a public MIT dataset of 2,023 unique glTF 2.0 Binary meshes (2,024 GLB files, 33.5 GB) for robot/cobot simulation, manipulation research, VLA training and benchmarking. Languages: Python.

How the work relates

The map shows protocol interfaces, libraries, tools, and assets. Applications select the components they need.

NCP connects Engram, CREBAIN, Prisoma, and Galadriel through local interfaces. Haldir keeps a separate NCP 1.0 interface. A long dashed line with a filled arrowhead carries CREBAIN sensor data to Prisoma. Dashed lines with open arrowheads point to libraries: Galadriel and Prisoma use pid-rs, and Engram uses Cortexel. Grey lines mark candidate inputs to CREBAIN without an adapter: the cobot-atlas and relief-atlas datasets and the Melkor and Manwe tools.

Open diagram · zoom and explore · Original SVG: light · dark

Read the connections: Filled arrowheads show where data, assets or messages go. Open arrowheads point to a library that a project uses.

  • Local NCP interface: solid paired arrows for requests and results on each owner's own process channel.
  • Uses a library: dashed line with an open arrowhead at the library.
  • Sensor data path: long dashed line with a filled arrowhead toward the recorder.
  • Haldir: NCP 1.0 interface: dash-dot line with a square end, outside the local v1 profile.
  • Mesh dataset: dotted line with a filled arrowhead toward the simulator.
  • Asset or model tool: dashed line with a filled arrowhead toward the simulator.

CREBAIN has no pid-rs dependency. Its recordings reach pid-rs through Prisoma's optional information analysis. Engram renders its figures through Cortexel's figure contracts.

Different jobs: Engram runs neural models. CREBAIN runs a standalone 3D environment and sensor fusion. Galadriel optionally checks sensors for possible tampering. Prisoma organizes experiments and evidence for embodied agents. NCP defines their shared messages.

Neural loop: Engram runs NEST networks. It sends action proposals to the CREBAIN body simulation and receives sensor data through NCP.

CREBAIN and Prisoma: Prisoma records each command before CREBAIN executes it. It joins the related sensor and neural steps into one experiment record.

Local four-program composition. Engram, CREBAIN, Prisoma, and Galadriel can run together as one local experiment. Each program owns its state.

The Engram source is in the private Paper2Brain repository. The public Engram repository is a placeholder. Read about NCP.

Components and sensors

CREBAIN runs standalone. Applications can add Engram neural models, Prisoma recording, or Galadriel monitoring. One endpoint can expose several identified sensors.

Each camera and microphone keeps its identity and timing. Prisoma defines features, source groups, targets, and statistical assumptions. pid-rs estimates the declared quantities for two to four source variables. NCP does not limit the number of sensors.

cobot-atlas supplies robotics meshes, and relief-atlas supplies disaster-relief and defense meshes for CREBAIN scenes. Melkor converts Gaussian-splat scenes for CREBAIN and wraps external reconstruction programs. Manwe makes perception models for CREBAIN sensors.

The four-owner reference routes CREBAIN observations to Engram and returns its action proposals. Galadriel records diagnostics, and Prisoma captures complete exchanges. Applications can select smaller compositions through the modular interface.

Engram coordinates one local experiment and owns the neural state. CREBAIN owns the body and fusion state. Prisoma records the step pairs. Galadriel records the detector output.

Each owner exchanges bounded requests and results through its own private process channel. NCP defines the shared contract.

Galadriel compares at least two sensor modalities. It reports when the evidence is not sufficient.

Scope: The composition runs in local simulation. Haldir authorizes commands through its own NCP 1.0 interface, outside this composition. Capture and monitor results never send commands.
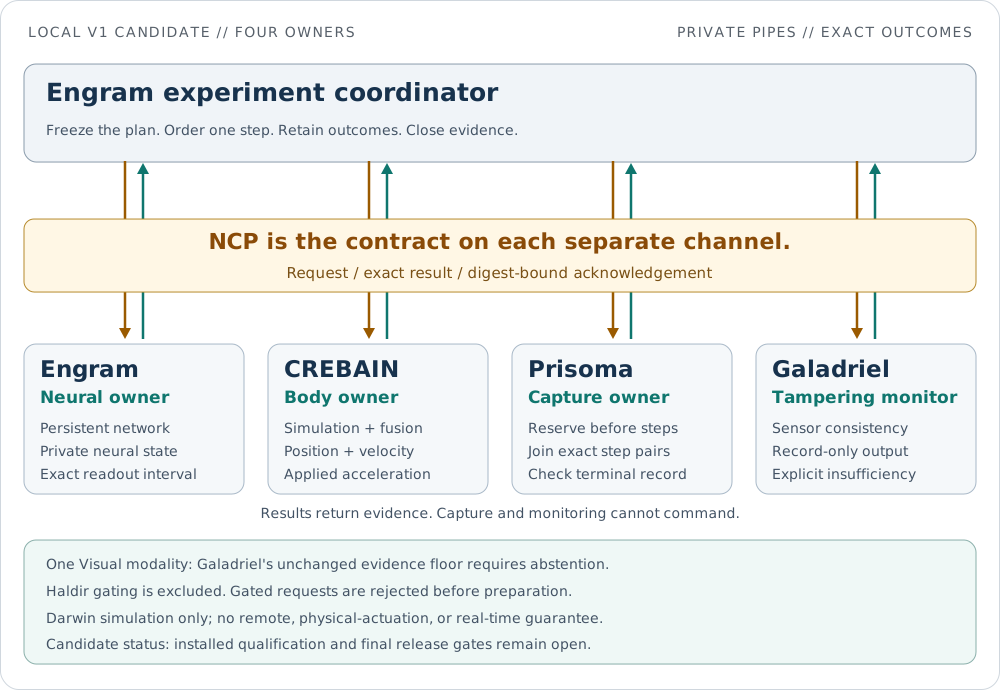
Engram coordinates one local experiment and owns the neural state. CREBAIN owns the body and fusion state. Prisoma records the step pairs. Galadriel records the detector output. The composition runs in local simulation. Haldir authorizes commands through its own NCP 1.0 interface, outside this composition. Capture and monitor results never send commands.

Open diagram · zoom and explore · Original SVG: light · dark

More repositories — public research code and tools


More public repositories; a detailed link list follows.

↗  brojapid-activationfunctions · mahmoudian-2020-rescience · nest-simulator · relief-atlas · silmaril-vision-studio

The toolbox — languages, frameworks and infrastructure


AI / ML stack: Python, PyTorch, NumPy, Pandas, SciPy, Pydantic, scikit-learn, Jupyter
Python    PyTorch    NumPy    Pandas    SciPy    Pydantic    scikit-learn    Jupyter
Backend & Systems stack: Rust, C, C++, FastAPI, Drizzle ORM, PostgreSQL, gRPC, Zenoh
Rust    C    C++    FastAPI    Drizzle ORM    PostgreSQL    gRPC    Zenoh
Cloud & DevOps stack: Cloudflare, Google Cloud, AWS, Docker, Kubernetes, Terraform, GitHub Actions, Linux
Cloudflare    Google Cloud    AWS    Docker    Kubernetes    Terraform    GitHub Actions    Linux
Frontend & Web stack: JavaScript, TypeScript, React, Vite, TanStack, Tailwind CSS, Vitest
JavaScript    TypeScript    React    Vite    TanStack    Tailwind CSS    Vitest

Agentic engineering — the AI-agent development stack

Agentic stack manifest: Ghostty (terminal, GPU-native); herdr (multiplexer, agent herd); OMP (lead harness, turbocharged Pi with batteries included); Devin (harness, long-horizon); Zed (editor, collaborative IDE).

Elsewhere — contact channels

Open channel: reach me at sepmhn@gmail.com; always open to interesting problems.

Pinned Loading

  1. crebain crebain Public

    Drone simulation with RGB, acoustic, and thermal sensors, native checkpoints, and optional NCP interfaces. Research prototype.

    Rust 22 1

  2. engram engram Public

    Engram Neural Modeling Labs: NEST and NCP experiments. Public source is pending; this repository is a placeholder.

    15

  3. NCP NCP Public

    Typed protocols for neural simulators, sensors, and closed-loop experiments. Local SDKs and a network protocol candidate.

    Python 16 1

  4. melkor melkor Public

    C++17 toolkit for 3D Gaussian splats: deterministic conversion, inspection, geometry-based scene completion and viewing across PLY, SPZ and glTF, with CPU/Metal and optional CUDA backends. v2 harde…

    C++ 13 1

  5. pid-rs pid-rs Public

    Safe Rust estimator core for categorical shared-exclusions PID (SxPID), KSG mutual information, and default-off experimental continuous PID. Optional Python bindings. v0.9.0 source-review prerelease.

    Python 15 2

  6. cobot-atlas cobot-atlas Public

    Python generation pipeline behind a public MIT dataset of 2,023 unique glTF 2.0 Binary meshes (33.5 GB) for robot/cobot simulation, manipulation research and VLA training. Published on Hugging Face…

    Python 7