Repository navigation
Restore V2 base motor collision clearance - #140
Merged
Merged
Conversation


There was a problem hiding this comment.
Copilot wasn't able to review any files in this pull request. Check if the Files changed in this pull request are included in default exclusions.


kou
pushed a commit
to enactic/openarm_mujoco
that referenced
this pull request
Nov 18, 2026
Replaces #103; submitted from `stevenaya/openarm_mujoco`. Replace the coarse V2 collision meshes with the split assets from [openarm_description](https://github.com/enactic/openarm_description/tree/38c64af1dd6f3bc246883754875cbb4259dce0fc/assets). Built on #105, which is now merged into `master`. ## Changes | Component | Collision pieces | | --- | ---: | | Shoulder base | 2 | | link2 / link3 | 3 each | | link4, including cable covers | 4 | | link5 | 9 | | link6 | 6 | | Each finger | 5 | | Pedestal | 6 | | ZED mount | 2 | - Refresh link1 and retain the current single-piece gripper base. Add the ZED body's collision using its existing official mesh and pose. - Store assets under `collision/arm`, `gripper`, `body`, and `zed_mount`; update references and the existing left-mesh mirroring script. - Retain the Cell's rotated shoulder-base installation. Cell frame and lifter collisions are unchanged. - Collision STL storage decreases from 2.04 MiB to 1.08 MiB; input triangles decrease from 42,806 to 22,516, including mirrored copies. The finger assets are five closed mesh pieces; [MuJoCo evaluates each piece's convex hull](https://mujoco.readthedocs.io/en/stable/XMLreference.html#asset-mesh) separately. ## Base motor clearance Restore the historical `Y = -61.5 mm` cutoff on the motor collision piece. The CAD-derived split had reinstated the removed 1 mm nose, causing a base/link1 overlap that blocked joint1 in fixed-base models. Both right and mirrored-left meshes retain 316 triangles. The matching source correction is [openarm_description #140](enactic/openarm_description#140). With collision filtering unchanged, both joint1s move to ±0.5 rad in native MuJoCo 3.8.1 and Web 4.0.1. A 101-position sweep per side finds no motor/link1 contact and at least 0.926 mm axial clearance. ## Visual comparison Before: #105 (`3b90f8d`). After: `cabf000`. Matching camera and joint poses; collision hulls are shown opaque. Colors distinguish finger pieces. | View | Before | After | | --- | --- | --- | | Complete pedestal robot | 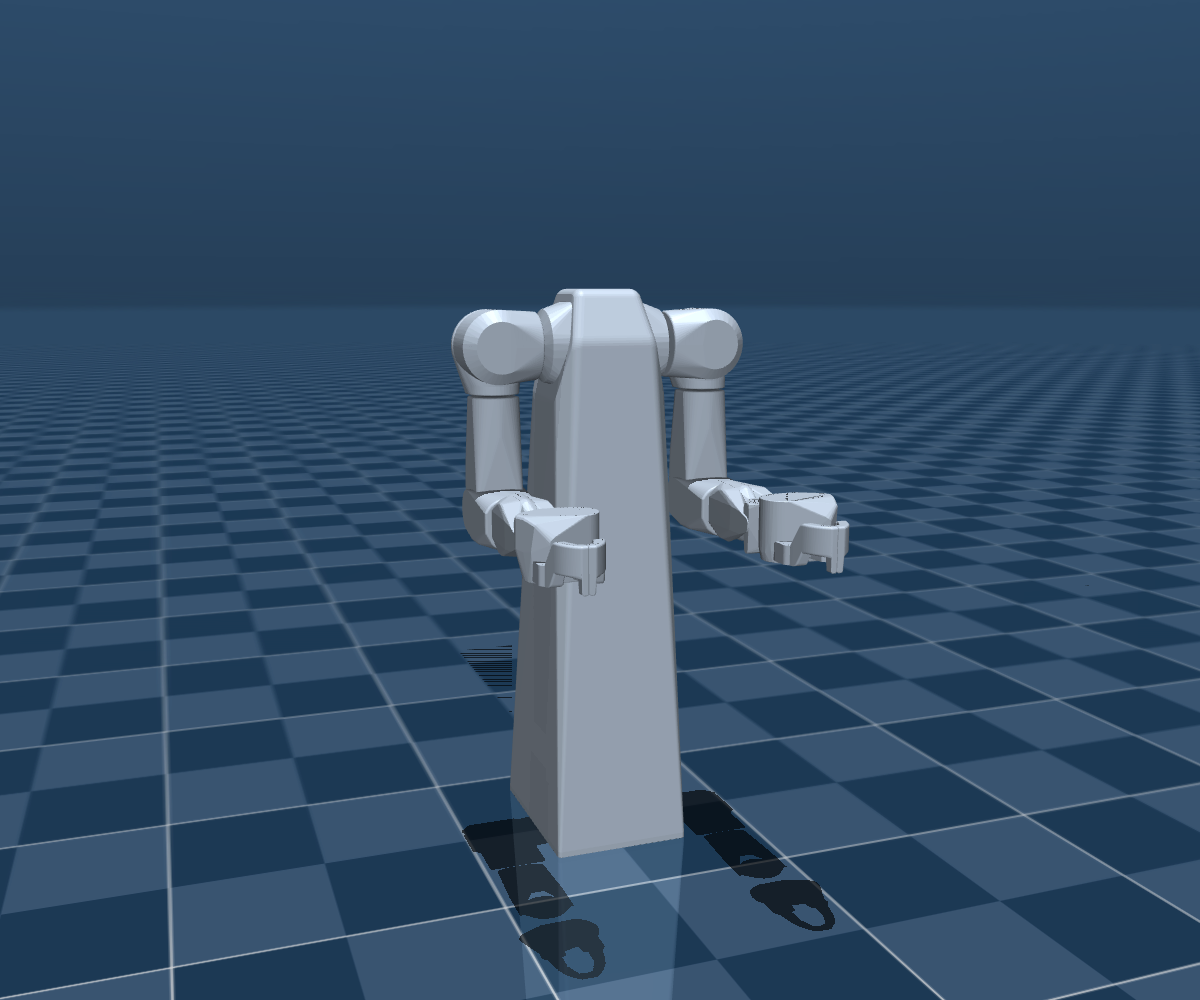 | 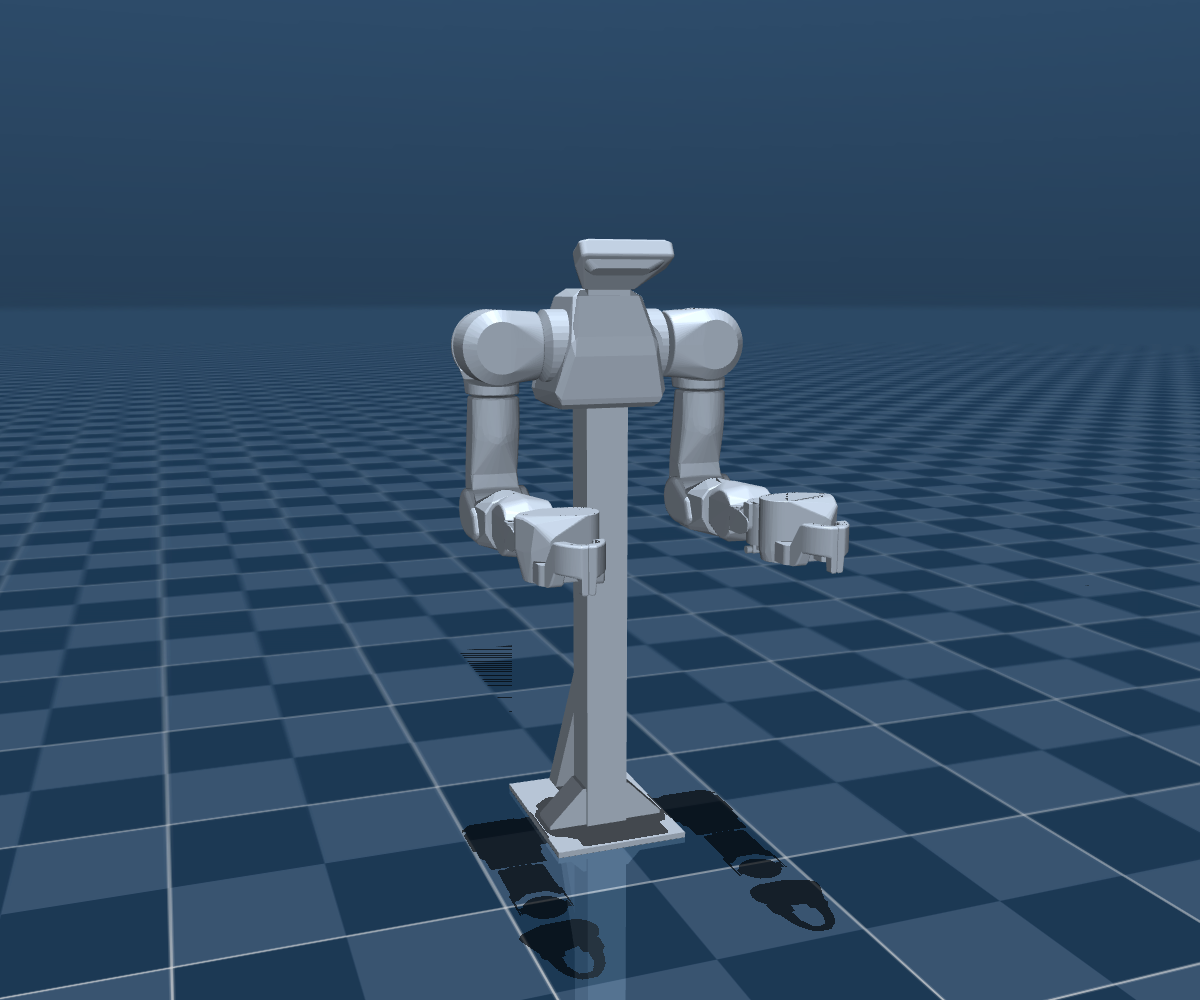 | | Pedestal and head camera | 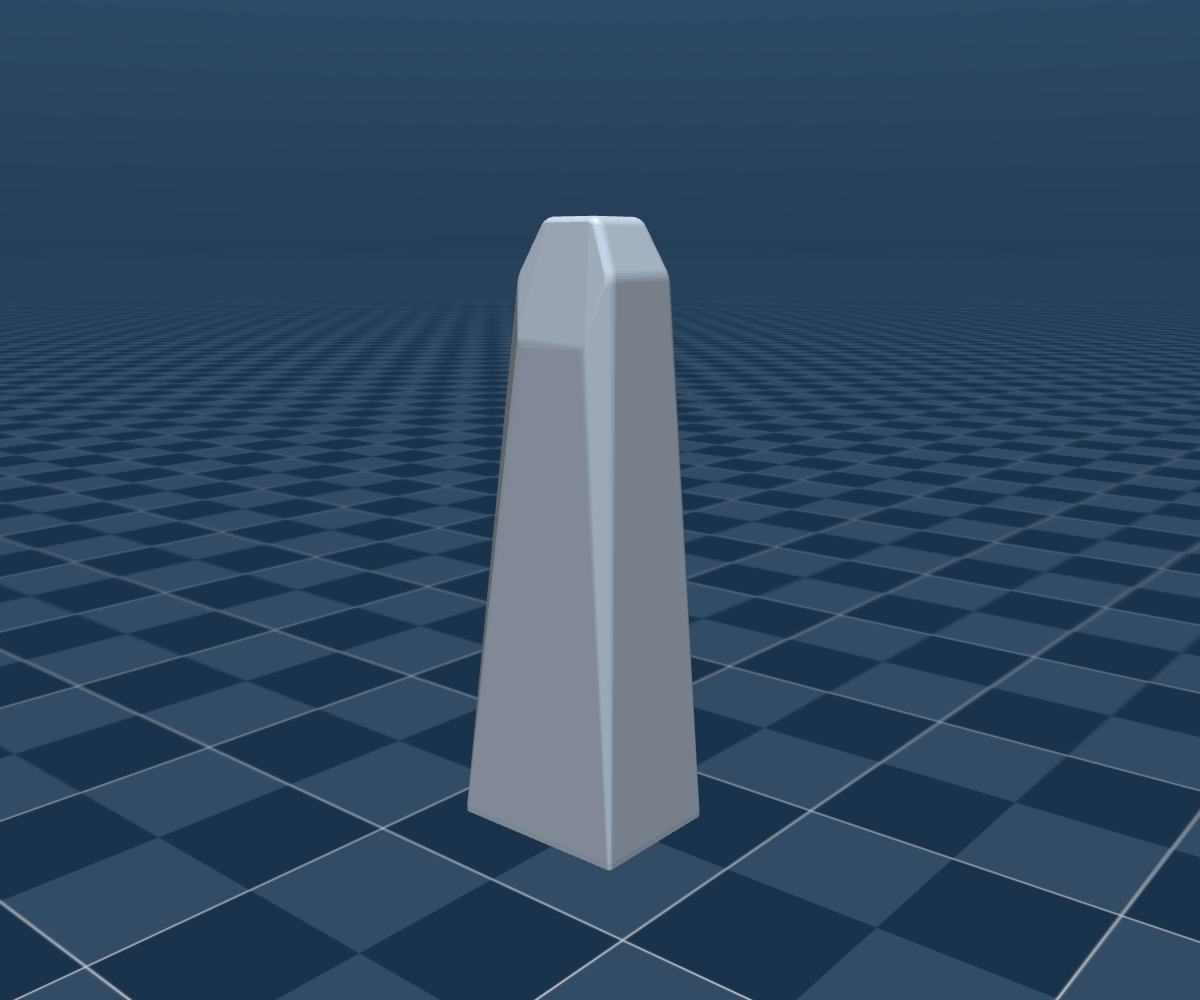 | 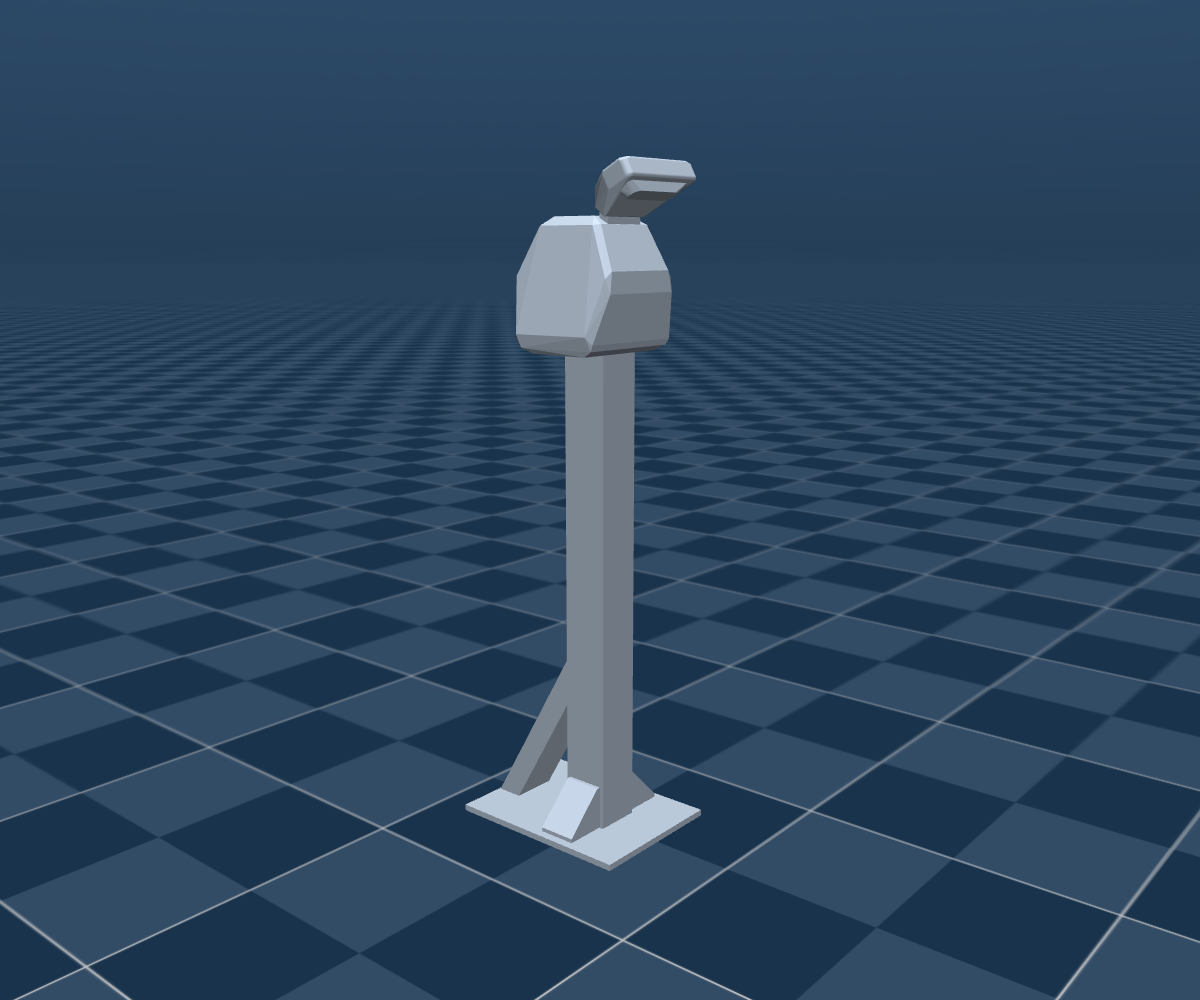 | | Gripper and fingers | 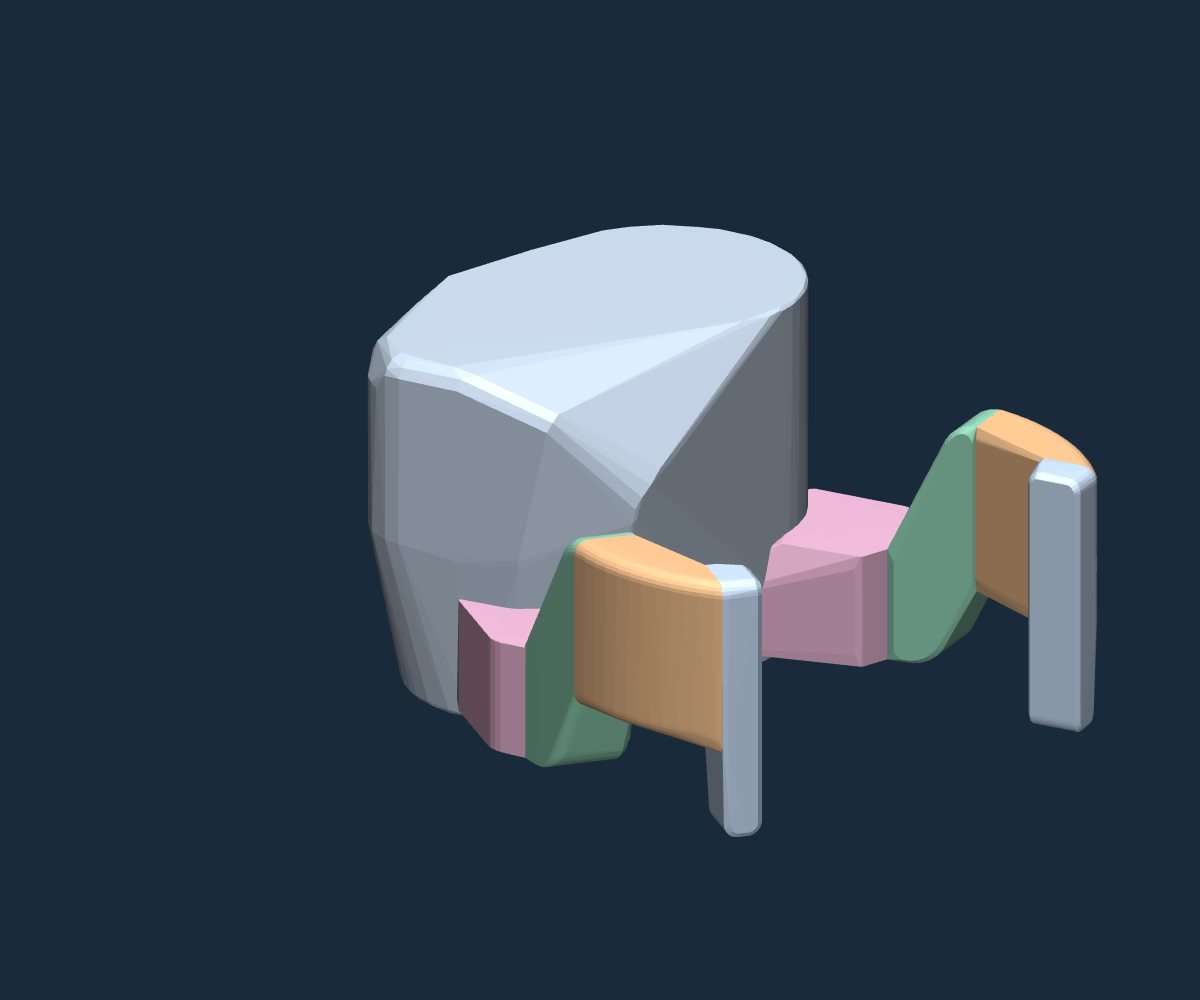 | 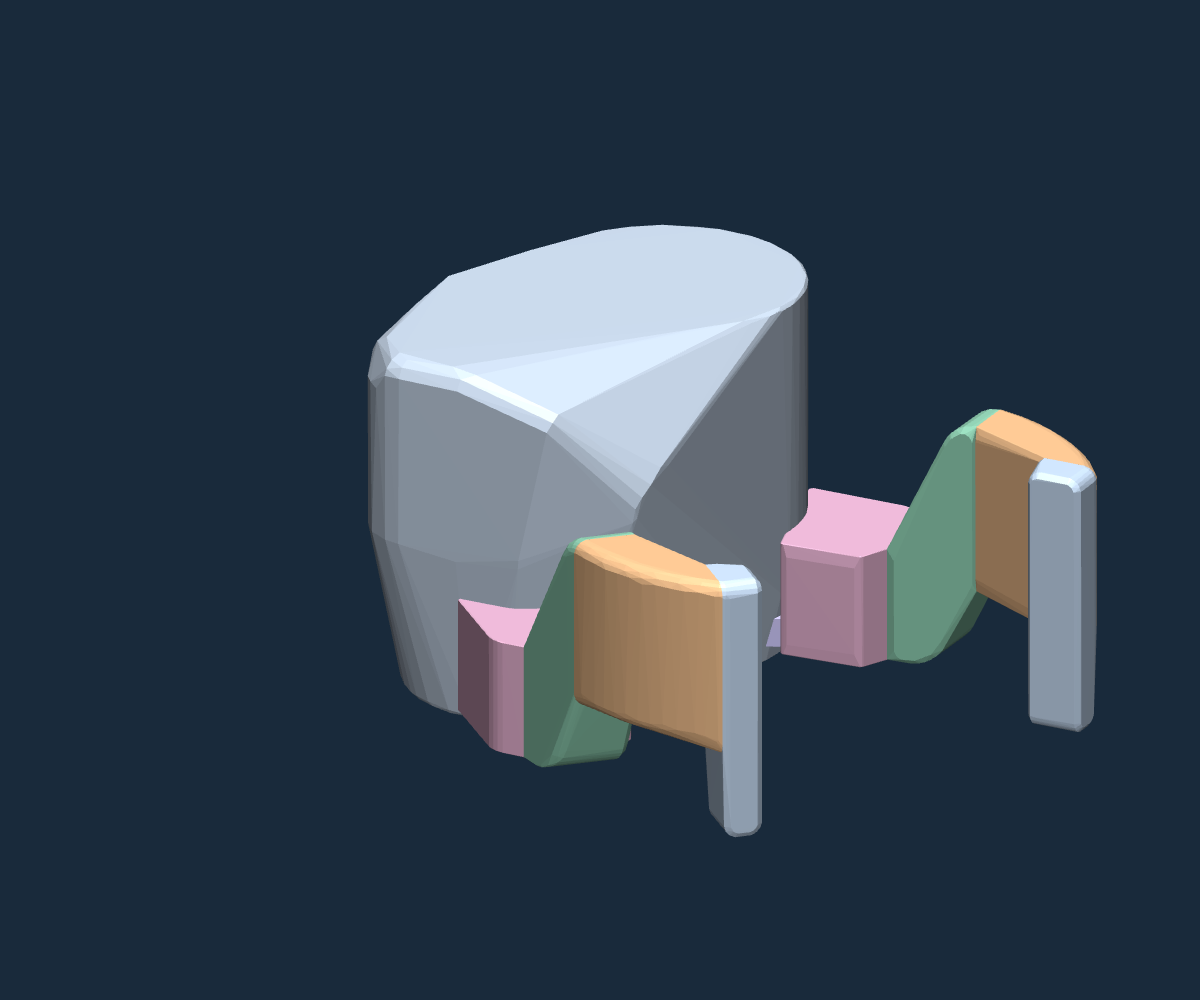 | ## Validation - All 79 collision STLs are closed, consistently wound, and free of degenerate faces; 32 mirrored assets regenerate byte-for-byte. - Existing V2 model/scene entries and the Cell-specific bimanual entry load. Robot, pedestal and Cell run 1,000 steps without warnings. - A 17-pose comparison preserves visual and camera transforms, body mass properties, mass matrices, bias forces and control parameters. - Existing Python tests (3), Web Node test files (4), and Ruff checks pass.

This branch was successfully deployed
This file contains hidden or bidirectional Unicode text that may be interpreted or compiled differently than what appears below. To review, open the file in an editor that reveals hidden Unicode characters.
Learn more about bidirectional Unicode characters
Sign up for free
to join this conversation on GitHub.
Already have an account?
Sign in to comment








Add this suggestion to a batch that can be applied as a single commit.This suggestion is invalid because no changes were made to the code.Suggestions cannot be applied while the pull request is closed.Suggestions cannot be applied while viewing a subset of changes.Only one suggestion per line can be applied in a batch.Add this suggestion to a batch that can be applied as a single commit.Applying suggestions on deleted lines is not supported.You must change the existing code in this line in order to create a valid suggestion.Outdated suggestions cannot be applied.This suggestion has been applied or marked resolved.Suggestions cannot be applied from pending reviews.Suggestions cannot be applied on multi-line comments.Suggestions cannot be applied while the pull request is queued to merge.Suggestion cannot be applied right now. Please check back later.
Restore the historical
Y = -61.5 mmcutoff on the V2 base motor collision piece. Rebuilding the two-piece representation from CAD had restored the nose to-62.5 mm, creating an overlap with link1 that locks joint1 in fixed-base MuJoCo models.Changes
Mesh comparison
Matched views of the actual STL geometry. Red and green highlight the old and new end faces. The end face moves inward by 1 mm; its area increases because the cut intersects the tapered nose. Both versions contain 316 triangles.
The section through X = 0 shows the removed 1 mm region. The zoomed axes use different scales for clarity.
Validation
The corresponding MuJoCo mesh and left-side mirror are updated in openarm_mujoco #106.