

A parametric tool for robot design exploration
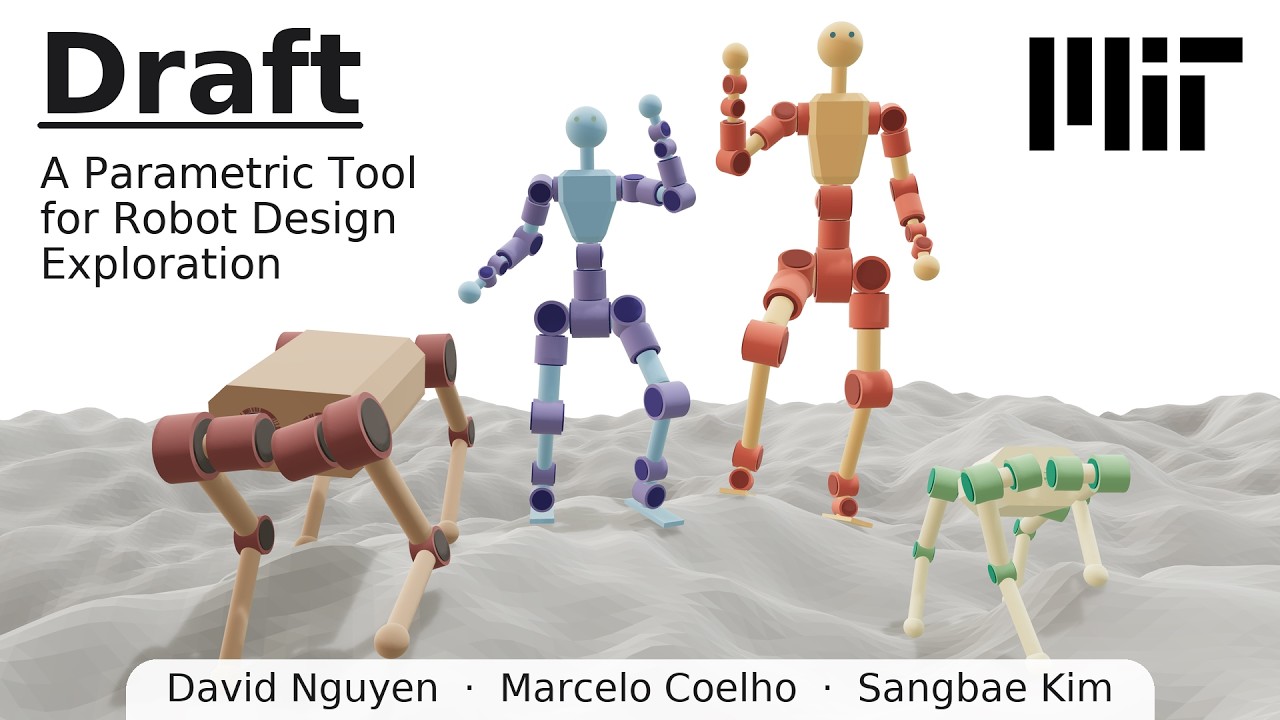
Draft compiles a short declarative robot description into a simulation-ready MuJoCo model, without CAD. You state link lengths and the torque and speed each joint needs. Trends fitted to 114 catalogued actuators and 49 published robot descriptions fill in the masses, motor sizes and reflected inertias, then check whether the assembled machine could be built. Design variants take seconds to generate, and every one can be trained with the included quadruped RL tasks.
This fork adds parametric 18-DoF hexapod robot generation and rough-terrain locomotion training in MuJoCo using mjlab and rsl_rl.

- Hexapod Morphology & Presets: Extended Draft's compiler with radial polygon lofting, mirror rotations, and geometric link sizing to generate 18-DoF radially symmetric hexapod variants (
beetle,strider,tarantula). - Scaling Laws & Trends: Fitted mass composition models, reflected inertia estimations, and structural feasibility checks for multi-legged hexapod kinematics.
- Locomotion Tasks & RL Environments: Built sprawled hexapod RL environments in
mjlabwith tripod gait rewards, foot clearance penalties, and an adaptive terrain curriculum across swells, rubble, inclines, and stairs. - Tooling & Visualization: Added multi-preset rendering tools (
scripts/figures/render_hexapods.py), checkpoint-aware policy playback (scripts/play.pywith auto-matching ground/terrain), and training CLI overrides.
conda env create -f environment.yml && conda activate draft
export PYTHONNOUSERSITE=1          # keep ~/.local packages out of the env
pip install -e ".[editor,twins,figures,dev]" -c constraints.txt
python scripts/robot_tuner.py                       # browser editor
python scripts/generate_robot.py --robot quadruped  # headless, writes generated/
Training needs a CUDA GPU: add the rl extra (pip install -e ".[rl]" -c constraints.txt) and see docs/tasks.md.
Everything else runs on a laptop CPU.
src/draft/
  generation/   the compiler: parameter table + kinematic tree -> MJCF
  trends/       fitted trends, the feasibility checks, and their coefficients
  robots/       the shipped specifications (humanoid, quadruped)
  twins/        four Unitree robots rebuilt from specs and scored
  tasks/        quadruped locomotion environments and curricula
  lineup/       the paper's training and evaluation sweep
  editor/       the browser editor
datasets/       actuator catalogue and robot-description survey, with fitting scripts
experiments/    design variants, sweep spec, frozen results
scripts/        command-line entry points and figure scripts
tests/          pytest; --runslow adds the twin rebuilds
Vendor robot models are not included. python scripts/setup_data.py fetches
them. The full documentation is in docs/.
If you use Draft or its datasets, please cite the paper:
@article{nguyen2026draft,
  title         = {Draft: A Parametric Tool for Robot Design Exploration},
  author        = {Nguyen, David and Coelho, Marcelo and Kim, Sangbae},
  journal       = {arXiv preprint arXiv:2609.38405},
  year          = {2026},
  eprint        = {2609.38405},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2609.38405}
}MIT, see LICENSE. Fetched vendor descriptions keep their own licences.