

A Modern Simulation Wrapper for Google DeepMind’s MuJoCo
⚠️ WARNING
This package is currently in its zero-release stage. Class methods and APIs may change without prior notice. Please review the documentation and changelog after each update to stay informed about any modifications.
Add -U flag to upgrade pre-existing library

pip install mujoco-toolbox
pip install git+https://github.com/MGross21/mujoco-toolbox.git@mainClick to Expand
Place the following in your requirements.txt or pyproject.toml file.
Expect less frequent, stable releases.
mujoco-toolbox
Expect frequent rolling releases.
git+https://github.com/MGross21/mujoco-toolbox.git@main#egg=mujoco-toolbox
FFMPEG
Required for mediapy dependency
Windows
winget install ffmpeg
ffmpeg -version
Linux
Debian/Ubuntu
sudo apt update && sudo apt install ffmpeg
ffmpeg -version
Arch Linux
sudo pacman -Syu ffmpeg
ffmpeg -version
MacOS
Using Homebrew
brew install ffmpeg
ffmpeg -version
Using MacPorts
sudo port install ffmpeg
ffmpeg -versionBare minimum to run MuJoCo simulation and display result
import mujoco_toolbox as mjtb

mjtb.Simulation("path/to/your/xml").run(render=True).save()run() records MjData fields at data_rate captures per second. Each field is an array of shape (captures, *field_shape).
import mujoco_toolbox as mjtb

sim = mjtb.Simulation("path/to/xml", duration=5, data_rate=100, capture={"time", "qpos", "xpos"}).run()
sim.captured_data["qpos"]  # (500, nq)
sim.body_data("arm", "xpos")  # (500, 3)
Omit capture to use mjtb.CAPTURE_PARAMETERS, or pass capture="all" to record every numeric field.
The following controllers are available out-of-the-box:
sincossteprandomreal_time(recommended controller for digital twins)
You can import them as follows:
import mujoco_toolbox.controllers as ctrldef foo(model: MjModel, data: MjData,**kwargs):
# Perform logic based on model/data objects
# ie. PID ControllerExtra keyword arguments to Simulation are passed to the controller on every step:
mjtb.Simulation("path/to/xml", controller=mjtb.sin, amplitude=0.5, frequency=2).run()import mujoco_toolbox as mjtb
from mujoco_toolbox.controllers import real_time
with mjtb.Simulation("path/to/xml", controller=real_time) as digitaltwin:
viewer = digitaltwin.launch(show_menu=False) # Open the simulation window
while not viewer.done(): # until the window is closed (or ESC/Q)
with digitaltwin.data_lock:
digitaltwin.controller(digitaltwin.model, digitaltwin.data, {"mjdata_kwargs": value})See MjData objects here
import mujoco_toolbox as mjtb

mjtb.Simulation("path/to/xml").show()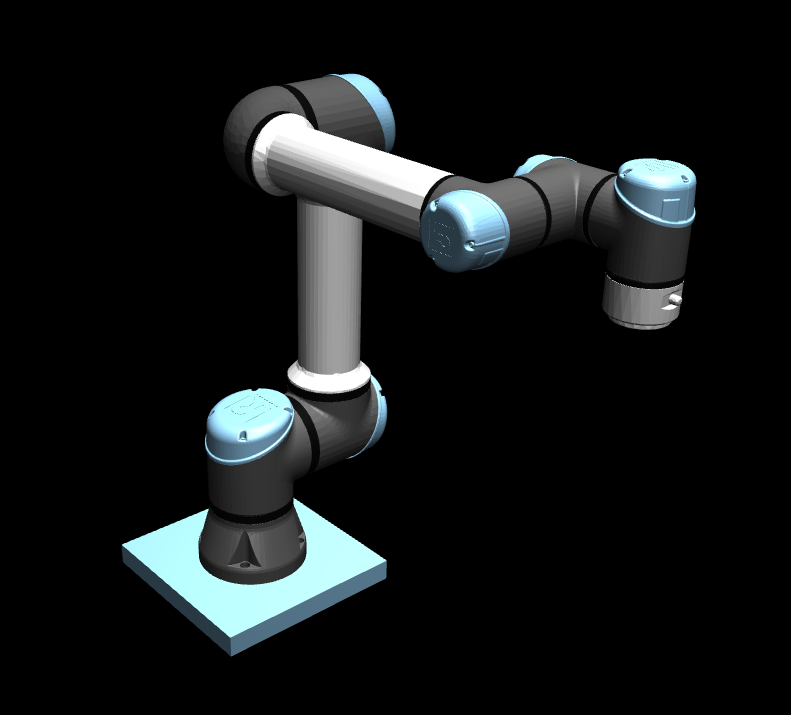
import mujoco_toolbox as mjtb

mjtb.Simulation("path/to/urdf", meshdir="path/to/mesh/files").show()  # supports *.stl or *.obj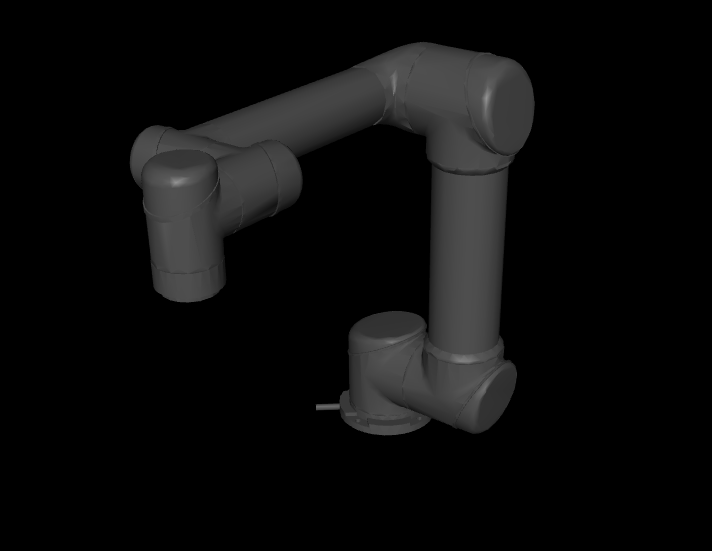
Supports full <mujoco>...</mujoco> and <robot>...</robot> structure as well as complete sub-tree structures.
import mujoco_toolbox as mjtb

# Merges: XML & URDF Files, XML & URDF Strings, Sub Tree Structures
mjtb.Simulation("path/to/xml_1", string_xml_var, ..., "path/to/xml_n").show()
⚠️ WARNING
Duplicate sub-tree items with the same name will cause MuJoCo to throw aFatalError.